From MASS Code to Maritime Practice
As shipping becomes increasingly automated, the International Maritime Organization (IMO) has introduced legislation to ensure future technology is safe and secure. Liam Talbot, co-chair of our Maritime Autonomous Surface Ships Special Interest Group (MASS SIG) discusses the challenges in taking the new rules from policy to practice.
The adoption of the International Maritime Organization’s MASS Code marks an important step in the development of maritime autonomy. Adopted at Marine Safety Committee (MSC) 111, it applied as a non-mandatory code from July 2026, with a mandatory code targeted for 2032.
The next, and arguably more difficult step, is translating that framework into real vessels, systems and operations. The MASS Code is deliberately goal-based and rather than prescribing a single technical architecture, it establishes goals, functional requirements and expected performance across areas including operational context, system design, software, remote operations and the human element.
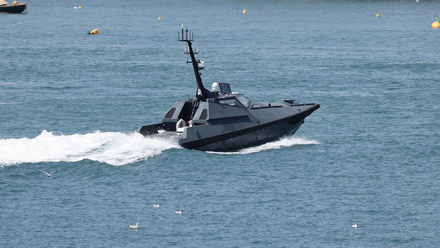
This is a sensible approach as maritime autonomy covers everything from small uncrewed survey vessels to large remotely operated ships, and technology is developing too quickly for a regulation built around particular technical solutions. However, the consequence of this approach is that considerable work remains between a requirement in the Code and an engineer demonstrating that a particular system satisfies it.
Consider the Operational Design Domain (ODD) which the Code defines as the "design range in which a system can operate as intended". This includes ephemeral (short-term) and environmental conditions, geographical constraints and the condition of the vessel itself. However, the ODD is the clearest example of the translation problem, not least because almost every other requirement in the Code ultimately depends on it.
A key consideration is how an autonomous vessel responds when conditions fall outside its ODD, for instance due to bad weather. The Code addresses this through fallback states and contingency measures intended to maintain safety when the system can no longer operate as intended.
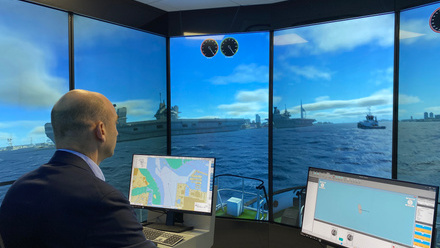
That sounds straightforward on paper but is possibly the most complex part of the Code. What environmental parameters define the boundary? How does the vessel determine that it is approaching the limits of its assured operation? What evidence demonstrates that the fallback behaviour remains safe? And more importantly, how do those claims connect to the testing, simulation, software assurance and operational evidence accumulated throughout the vessel's lifecycle? For a coastal survey vessel these questions are demanding. For a harbour tug working amongst crewed traffic, they become considerably harder.
These questions aren't arguments against the Code, they're precisely the questions that a goal-based code should pass to industry, regulators and the engineering profession to tackle.
The challenge facing our community is no longer writing the rules, but translating them, and the next step for the maritime autonomy community should be to develop a common engineering interpretation between the regulatory requirement and its practical implementation. For each relevant requirement, we should be able to trace a path from the intent of the Code through the functions required to satisfy it, the evidence needed to support the claim, and the organisations or individuals responsible for providing and accepting that evidence.
This traceability matters because operation of MASS will likely depend simultaneously on onboard autonomy, communications, the remote operations centre, suitably qualified and experienced personnel, port infrastructure and external information services. These need to be considered as a whole, as examining each component independently risks missing the interfaces between them.
There is also a wider risk, and subsequent opportunity. If every operator, supplier, class society and regulator independently translates the MASS Code into their own architecture, taxonomy and assurance framework, the sector risks becoming fragmented. Proprietary approaches will matter, but there is value in establishing a common, vendor-neutral foundation on which those approaches can build.
This is where professional institutions, such as the IMarEST, can help provide that neutral ground. Through the MASS SIG, the Institute has an opportunity to convene the maritime autonomy communities around the practical implementation of the Code and capture lessons as autonomous operations move from controlled trials towards routine use.
Timing is also important because the current non-mandatory code provides an opportunity to accumulate operational experience before development of the mandatory code progresses. The objective shouldn't just be demonstrating that autonomous vessels work, it should be understanding how confidence in their operation can be established repeatedly and transparently.
Demonstrating maritime autonomy in a trial environment is one thing, but operating it routinely, and at scale, is another. Achieving that will require a vendor-neutral foundation of accepted operating boundaries, repeatable assurance frameworks, and clear responsibilities when circumstances change. The IMO MASS Code provides the regulatory framework, but now turning it into seaworthy systems is the challenge for the profession.